Orbit: Difference between revisions
From Rise: The Vieneo Province
(Describe powered ascent plan versus actual flight, flight-state modes and HDG/PIT guidance) |
No edit summary |
||
| (One intermediate revision by the same user not shown) | |||
| Line 1: | Line 1: | ||
The '''Digital Orbital Resolver (DOR)''' is the spacecraft's orbital guidance and control system. Its '''Orbit MFD''' shows your current trajectory, the selected target's trajectory, and a proposed maneuver around [[Vieneo]]. Use it to change your orbit, rendezvous with a station or another spacecraft, or pass over a selected surface point. '''DOR executes the selected valid orbital plan'''; circularizing is one possible plan. | The '''Digital Orbital Resolver (DOR)''' is the spacecraft's orbital guidance and control system. Its '''Orbit MFD''' shows your current trajectory, the selected target's trajectory, and a proposed maneuver around [[Vieneo]]. Use it to change your orbit, rendezvous with a station or another spacecraft, or pass over a selected surface point. '''DOR executes the selected valid orbital plan'''; circularizing is one possible plan. | ||
The full-page instrument is installed in the E-10, E-11, P-13, W-6, | The full-page instrument is installed in the E-10, E-11, P-13, W-6, and EVA displays. | ||
'''About the illustrations:''' These are labeled scenario renders from the implemented instrument's layout, orbital planner and guidance code, using synthetic example conditions. They are not screenshots of live flights. Each uses the native 420 × 320 layout enlarged for reading. Example times, fuel and delta-V are not a performance promise for your vehicle. Some dated illustrations use earlier labels (MIN ROUTE ALT, TO GO / USED and ATM PASS) and omit the live MECO estimate; the current readouts are described below. | '''About the illustrations:''' These are labeled scenario renders from the implemented instrument's layout, orbital planner and guidance code, using synthetic example conditions. They are not screenshots of live flights. Each uses the native 420 × 320 layout enlarged for reading. Example times, fuel and delta-V are not a performance promise for your vehicle. Some dated illustrations use earlier labels (MIN ROUTE ALT, TO GO / USED and ATM PASS) and omit the live MECO estimate; the current readouts are described below. | ||
Latest revision as of 18:49, 22 October 2026
The Digital Orbital Resolver (DOR) is the spacecraft's orbital guidance and control system. Its Orbit MFD shows your current trajectory, the selected target's trajectory, and a proposed maneuver around Vieneo. Use it to change your orbit, rendezvous with a station or another spacecraft, or pass over a selected surface point. DOR executes the selected valid orbital plan; circularizing is one possible plan.
The full-page instrument is installed in the E-10, E-11, P-13, W-6, and EVA displays.
About the illustrations: These are labeled scenario renders from the implemented instrument's layout, orbital planner and guidance code, using synthetic example conditions. They are not screenshots of live flights. Each uses the native 420 × 320 layout enlarged for reading. Example times, fuel and delta-V are not a performance promise for your vehicle. Some dated illustrations use earlier labels (MIN ROUTE ALT, TO GO / USED and ATM PASS) and omit the live MECO estimate; the current readouts are described below.
Ground rendezvous: Select MODE RENDEZVOUS on the ground to plan and fly VTOL launch, ascent, parking-orbit insertion and transfer to an orbital station or spacecraft as one DOR mission. See Ground-to-rendezvous mission. Standalone MODE PARKING ORBIT ends at the parking orbit. Ground-to-ground SURFACE PLAN remains planning-only.
Client versions and limits: Orbital adjustment, rendezvous and overflight have executable plans. SURFACE PLAN remains planning-only for ground and low-atmospheric departures. The automated-entry alpha adds REENTRY execution from orbit to an atmospheric handoff, followed by altitude, heading and TAS hold. It does not fly the final descent or land. This requires the client with ENTRY READY; earlier calibration clients show REENTRY PLAN / PLAN ONLY and support manual REC capture only.
Open and operate the page
The page is identified as DOR at the upper left. On the ground, the launch header shows SEARCH while comparing candidates and ARMED while DOR is awaiting comparison or departure. NO FIT or FUEL identifies an unavailable or fuel-short launch estimate. While executing, EXEC at the upper right and the active phase (ALIGN, WAIT, BURN, COAST or ARRIVAL) blink together: one second visible, one second hidden. Normal active phases are green; a separate red warning does not turn BURN or ARRIVAL red. The phase and its MECO estimate blink together. The DOR page identifier, other numerical readouts and atmospheric warnings stay steady. ESTIMATE, NO PLAN and completion/fault indications do not use this execution blink.
Older orbital illustrations show ORB1 and DOR-prefixed phases. Static illustrations do not demonstrate the execution blink.
Select the Orbit page on a supported vehicle's MFD. Choose the station, spacecraft or surface waypoint on your usual target-selection instrument; Orbit reads that selection. You do not enter a second waypoint on this page.
| Control | Action |
|---|---|
| Shift + Up / Down | Select a row in the side controls. The highlighted row's actions appear along the bottom. |
| Shift + Left / Right | Change the highlighted option or decrease/increase its value. |
| Shift + C, with the eccentricity row selected | Request a circular orbit (e = 0). |
| Your configured DOR on/off control | Engage or disengage a valid executable plan. SURFACE PLAN stays planning-only. The automated-entry alpha can execute an ENTRY READY reentry; after handoff, the same control cancels its TAS hold. |
The controls require cockpit power and do not take these keys while text entry is active. Changing VIEW does not alter the plan or interrupt DOR. Changing a planning value does interrupt execution: review the new solution before engaging DOR again. Standalone PARKING ORBIT offers STEER AFCS / ORBIT as a live heading-source choice during the climb. Ground RENDEZVOUS selects its staging orbit and orbital steering automatically.
Administrator diagnostics: REC and automatic local CSV capture are available only to administrator accounts. Other accounts have no REC row and their DOR flights are not recorded automatically. Losing administrator permission ends an active capture without changing DOR guidance.
Selecting Orbit does not replace or acknowledge EICAS indications. With EICAS powered and serviceable, its gear, engine, trim and crew-alert indications remain independent of the MFD page. If these disappear only while ORB1 is selected, that is a rendering fault, not evidence that the underlying condition has cleared.
Select an objective
| MODE | Use |
|---|---|
| RENDEZVOUS | An orbiting station or free-flying vessel is selected. Reach its trailing staging point and match its velocity. On the ground, this includes launch, ascent and insertion followed automatically by the orbital transfer. |
| OVERFLY | A surface waypoint or grounded vessel is selected. Pass above that rotating ground point at the requested altitude and time. |
| SURFACE PLAN | A surface target is selected for a ground or low-atmospheric departure. Compare atmospheric, suborbital and orbital journeys using TRIP duration before departure and a PASS countdown afterwards. Planning only. |
| REENTRY | The surface-arrival objective for an orbital/high-altitude departure, including while docked at a station. Compare direct powered entry with coast-then-entry, ending upstream of the waypoint at the selected HANDOFF altitude and TAS. The automated-entry alpha can execute a qualifying ENTRY READY plan after undocking. |
| PARKING ORBIT | Before orbit is established, perform VTOL liftoff or take over an airborne climb to a selected circular parking orbit. Main-engine pitch guidance uses current mass and atmospheric conditions. This standalone mode ends at insertion; choose RENDEZVOUS before launch for the continuous trip to an orbital target. |
| ADJUST ORBIT | Change your own orbit independently of the selected target. Available through MODE once the current bound orbit has its periapsis above the surface, including when a target is selected. It is not offered on the ground. |
A newly selected surface target defaults to the surface-arrival objective. It is labeled SURFACE PLAN for a ground/low-atmospheric departure or REENTRY for an orbital/high-altitude departure. An entry keeps its identity through the atmospheric handoff rather than becoming a new ground-departure plan. Use MODE to choose OVERFLY for an orbital pass or ADJUST ORBIT to change your own orbit. An explicitly selected ADJUST ORBIT objective remains independent of the target.
With an orbital target selected on the ground, MODE offers RENDEZVOUS and PARKING ORBIT. Once established in a bound orbit with periapsis above the surface, it offers RENDEZVOUS and ADJUST ORBIT; PARKING ORBIT is no longer offered. Without a target, choose PARKING ORBIT before orbit is established, ADJUST ORBIT in orbit, or select a navigation target elsewhere. A docked or contained target is not treated as an independent free-flying spacecraft. An undocked spacecraft inside a station's control area remains a valid target. An atmospheric-flight target may still have a predicted trajectory, but it is marked with an atmospheric warning.
Rendezvous is more than matching orbital size and shape. Two spacecraft can have identical orbital parameters and remain far apart. Rendezvous also solves for position and velocity at the same future time, including the difference between their orbital planes.
Read the picture and numbers
The graphic area stays the same size in every mode. In the ascent altitude/distance view, green is measured flight history and amber is the powered forecast (see Ground and ascent). In orbital views, green is your current trajectory; cyan is the target; amber dashed lines show the proposed transfer. Dim amber shows the destination orbit, and gray dashed lines show a planned coast before departure. AP and PE mark apoapsis and periapsis. In orbital plans, numbered amber markers identify burns; T identifies the target's current position. Ground-departure surface previews instead number phase boundaries and mark the future arrival point B. REENTRY uses D for deorbit, E for the 100 km crossing and H for atmospheric handoff; the legend identifies them.
| VIEW | What it helps you see |
|---|---|
| ORBIT | Your orbital plane viewed face-on: shape, apsides and transfer path. |
| PLANE 3D | Plane orientation, with Vieneo's equator and north axis as references. The NODE line indicates the intersection of the current and target orbital planes. |
| EDGE-ON | Your orbital plane viewed from its edge. Useful for seeing how far the target or transfer leaves that plane; it compresses the shape of your own orbit into a line. |
| TRACK | Latitude/longitude ground tracks, including Vieneo's rotation. Useful for a surface overflight. This is a schematic grid, not terrain imagery. |
| Readout | Meaning |
|---|---|
| AP / PE | Highest / lowest altitude of the orbit above the spherical Vieneo reference surface, in km. A negative PE means the unpowered trajectory intersects that surface. |
| e | Eccentricity: 0 is circular; larger values produce a more elongated ellipse. |
| SIZE … km MSL | Orbit size expressed as altitude above mean sea level. For a circle, this is the orbit altitude; for an ellipse, it is (AP altitude + PE altitude) / 2, not the time-average altitude. The planner adds Vieneo's 2939.6 km reference radius internally. |
| i / PLANE DIF | Inclination to Vieneo's equator, or the angle between your plane and the target's plane, in degrees. |
| TP / nu | Orbital period in seconds / true anomaly in degrees, locating you around the current orbit relative to periapsis. |
| CURRENT > FINAL | Current AP/PE/e followed by the proposed final orbit after all burns. Older captures say CURRENT > PLAN. This is not the transfer minimum. CURRENT > REQUEST is an editable goal for which no valid plan exists yet. |
| PLAN MIN ALT | Lowest checked planned-route altitude in km MSL above the spherical reference surface. Includes any waiting coast, transfer and continuing final orbit; an OVERFLY circularization check also includes its arrival-response allowance. This is separate from final PE and from the actual unpowered coast. |
| B1 / B2 | Planned burn time and delta-V in m/s. The IDEAL line gives duration in seconds and fuel in kg for the main-engine maneuver; it does not include all attitude control, RCS trims or later corrections. |
| TOTAL / IDEAL FUEL | Total planned delta-V and ideal main-engine fuel. The calculation uses current vehicle mass and engine performance, with mass decreasing as fuel is consumed. Real execution can use more fuel for alignment, RCS, finite burns and corrections. |
| LEFT / ALL USED | During orbital DOR execution: the active guidance correction remaining, in m/s, and all fuel consumed since engagement, in kg. ALL USED includes the armed wait and ascent when starting from the ground, as well as alignment, both burns, coast and corrections; it is not a B1-only or B2-only measurement. |
| MECO ~mm:ss | Estimated time to cutoff of the current orbital burn, shown beside BURN or ARRIVAL. It follows measured convergence and throttle-down, not the original B1/B2 duration. It may increase after a correction. --- means no reliable recent convergence estimate. ALIGN, WAIT, COAST, continuous ascent and reentry do not show this timer. Cutoff is controlled by guidance, not by the countdown; another correction may subsequently fire. |
Minimum route altitude
Read PLAN MIN ALT directly below the graphic before engaging DOR. The graphic retains its size, and the OWN / TARGET / PLAN legend sits alongside the readout. It appears in every orbital view, including ascent detail when an orbital route is available. It uses the planner's checked arc minima, not the lowest vertex of the drawn curve.
- Red means the planned minimum is below 100 km MSL.
- Amber means the minimum is at least 100 km but the planned route has an atmospheric warning or is blocked by the clearance check.
- Neutral gray is an unflagged estimate, not flight clearance. --- means no checked route minimum is available; it never substitutes the final PE or current-coast minimum.
CURRENT > FINAL distinguishes the destination AP/PE from this route minimum. A final PE of 118 km does not establish the approach's minimum altitude, and pressure warnings depend on air-relative speed as well as altitude. The pressure advisory threshold is 10 Pa; a 118 km orbit is not automatically atmospheric. Atmospheric and surface-planning policies remain those of the selected mode; this display change does not add a new restriction to RENDEZVOUS or ADJUST ORBIT. SURFACE PLAN keeps its separate phase legend and planning-only readouts.
During EXEC, PLAN MIN ALT continues to describe the committed instantaneous-burn plan. COAST MIN describes the current unpowered trajectory if no more burns occur; CORRECTION MIN describes the live powered-correction forecast. These are km MSL and need not agree: a planned minimum of 118 km can coexist with a negative COAST MIN while later burns are still needed. A negative value means the mathematical coast intersects Vieneo. These warnings remain separate from the green execution phase and any retained red abort reason. A fresh preview after an abort shows the new plan; the old abort reason remains available independently.
Finite-burn limitation: PLAN MIN ALT still describes the instantaneous-burn plan, not the live powered recovery. DOR checks a finite powered response separately, including alignment time rather than an unpowered coast for the entire correction. A negative current PE during a burn can therefore coexist with a viable recovery, while still warning what would happen if thrust stopped. A neutral planned minimum or final PE is not assurance that DOR can complete the whole maneuver. See Powered correction clearance.

Orbital direction cautions
A steady amber caution beside the graphic's view title identifies the direction of the proposed plan. It remains visible during EXEC, including the hidden half of the execution blink, and does not replace atmospheric, fuel or finite-burn cautions.
- ORBIT REVERSAL means a departure or arrival burn changes the orbital angular-momentum direction by more than 90 degrees. It compares the directions before and after the burn; it is not based on which way the nose or thrust vector points. An ordinary backward braking burn that preserves orbital direction does not trigger it.
- RETROGRADE ORBIT means the transfer or final orbit runs against Vieneo's modeled rotation. A ship that already travels retrograde can keep that direction without an ORBIT REVERSAL. Polar motion alone is not classified as retrograde.
- RETROGRADE / REVERSAL shows both conditions. An intermediate retrograde transfer still warns even if the final orbit returns to prograde. The committed plan retains its caution during execution.
The OVERFLY automatic initial PASS search excludes plans that reverse orbital direction. Manual previews remain available with the caution. Direction caution alone does not block DOR, but the independent OVERFLY atmospheric-clearance requirements still apply. Blocked atmospheric previews retain their direction caution. If reversal was unintended, change the arrival/departure time or the overflight exit behavior and inspect the resulting plan before engaging DOR. A large delta-V can suggest reversal, but the warning is calculated from the trajectories rather than a speed threshold.
See the updated blocked-overfly illustration under Overfly atmospheric clearance. It replaces the older example that allowed the same low-periapsis route as a warning-only plan.
Ground and ascent
For a ground RENDEZVOUS or standalone PARKING ORBIT, the default ORBIT view shows ASCENT / ALTITUDE VS DISTANCE. The vertical axis is altitude in km MSL; the bottom axis is accumulated horizontal ground distance in km since departure. This is distance along the flown ground track, not range to the destination or slant distance. Taxi distance is excluded; a vertical VTOL climb remains at zero ground distance.
- PLAN EST (amber) is the estimated powered climb through insertion, using the ascent controller, current loaded mass, gear configuration, wind, atmosphere and engine limits. Computation runs in the background. COMPUTING PLAN... and PLAN UNAVAILABLE identify missing forecasts. It is an advisory estimate, with approximate aircraft response, fixed weather/configuration and no terrain or obstacle check.
- ACTUAL (green) is the measured flight history, with a diamond at the latest position. Samples are retained approximately every kilometre horizontally, or earlier after a kilometre of altitude change or five seconds, preserving slow and vertical flight. The display updates approximately once a second. Long histories are progressively coarsened while retaining the departure point.
- The departure plan stays fixed after liftoff so deviations remain visible. Changing the orbit/steering/target regenerates the remaining forecast from the current distance; FROM ... km identifies that starting point. The forecast may update on the pad as the launch recommendation or aircraft setup changes.
- History is collected for every pilot without REC, including manual departure. If observation starts airborne, DIST FROM PICKUP (km) identifies its origin. Landing, a vehicle/simulator change or a flight-state reset starts a new history. REC is separately restricted to administrators and writes diagnostic files.
The axes scale to fit both traces. The ascent profile remains available in the default ORBIT view through parking-orbit insertion, including above 100 km. Change VIEW to PLANE 3D, EDGE-ON or TRACK to inspect orbital geometry without cancelling the climb. At the RENDEZVOUS insertion handoff, the display changes to the transfer plan. The header says ASCENT / INSERTION during the initial leg.
With an orbital target selected on the surface, choose RENDEZVOUS for launch through arrival, or PARKING ORBIT to stop after insertion. ADJUST ORBIT replaces PARKING ORBIT once an orbit is established.
For a vacuum orbital objective such as ADJUST ORBIT, ASCENT PROFILE REQUIRED means that objective has no executable powered launch. Choose MODE RENDEZVOUS for a complete trip to an orbital target, or MODE PARKING ORBIT for a separate powered climb ending at a parking orbit. Older clients require manual ascent. Any ordinary vacuum transfer estimate starts from your measured position and velocity; it does not include lift or drag in that predicted path.
Outside an executable powered-ascent leg, the local ASCENT DETAIL / COAST view still shows the measured-state unpowered coast below 100 km. It returns to the selected orbital view at 100 km. This does not certify insertion: a periapsis intersecting Vieneo still indicates a suborbital trajectory. A descending vehicle is not automatically shown as ascending.
For SURFACE PLAN, the default view shows a fitting estimated powered ascent as ASCENT / PLAN ONLY. A rejected candidate is labeled ASCENT / INVALID PREVIEW. Change VIEW to PLANE 3D, EDGE-ON or TRACK to inspect the entire journey before takeoff; changing VIEW does not change the selected trip timing. The local surface view rotates with the departure location, so a vertical climb is not mistaken for sideways travel caused by Vieneo's rotation.
There is no hard atmospheric boundary at 75 or 100 km. The planner's warning estimate uses the client's density model and air-relative speed. The 100 km ascent-view transition is a display rule. OVERFLY separately uses 100 km as a minimum clearance policy and also checks dynamic pressure; neither use defines a physical atmospheric boundary.
Ground-to-rendezvous mission
Use this procedure to fly from the surface to an orbital station such as TAC without selecting a new plan in orbit.
- Select TAC on the navigation/target instrument and choose MODE RENDEZVOUS on DOR. Initially MEET shows FASTEST (AUTO) while DOR finds its earliest accepted arrival estimate. You can then adjust the countdown for a later or earlier meeting. DOR uses a 200 km MSL intermediate parking orbit and selects the target's orbital direction automatically; there are no ORBIT or STEER setup rows in this mission. STAGING 200km MSL / AUTO reports this intermediate goal, which is not the station's altitude or an optimized choice among parking altitudes.
- Review FACE ... deg T for the intended launch direction. The target's current bearing and closing range are not the required insertion heading or launch time. If ATC requires a different departure route, leave DOR off and fly that route manually; engage the retained rendezvous mission when cleared to proceed toward the orbital direction. Standalone PARKING ORBIT retains the optional HDG/NAV steering selection.
- Compare the launch recommendation, INSERT IN, ASC / XFER / TOTAL fuel and MEET -5m / +5m alternatives. During FINDING FASTEST RENDEZVOUS or COMPARING LAUNCH TIMES..., numbers may describe a provisional candidate; CANDIDATE / NOT COMMITTED is not a launch countdown. MEET must leave time for both ascent and transfer. A station that is close and approaching can still have no fitting solution at the chosen MEET.
- Leave LAUNCH AUTO to wait for the recommended departure. When VTOL is ready and automatic departure is authorized, engage DOR. It can remain armed while the comparison finishes, showing ARMED / COMPARING LAUNCHES with zero thrust and no attitude command. When a completed, current, fuel-fitting solution is available, ARMED / LAUNCH WAIT and LIFTOFF IN show its committed countdown. At zero, DOR starts VTOL automatically. LAUNCH NOW evaluates immediate departure only; RENDEZVOUS still waits for that completed, fuel-fitting estimate before liftoff.
- Start approximately level on a clear VTOL area with sufficient loaded vertical-thrust authority. Stow flaps and spoilers, close bays and clear icing. DOR lifts to approximately 100 m AGL, builds airspeed, and controls pitch and thrust through ascent and insertion. Retract the landing gear yourself after liftoff. Monitor IAS/Vne, AFT, fuel and the flight path.
- At settled insertion, leave DOR engaged. AUTO TRANSFER AFTER INSERTION means it will solve the transfer from the achieved orbit and remaining fuel, keeping the original absolute MEET. If an immediate transfer does not fit, DOR can select a checked coast before the departure burn while keeping MEET unchanged. The display changes from ascent controls to the orbital plan and burn guidance. No MODE change, manual replan or second engagement is needed.
- Continue monitoring through alignment, departure burn, coast and arrival correction. Successful rendezvous ends at the normal roughly 5 km trailing staging point and hands over to TVM with zero selected closing speed. Obtain clearance and perform close approach/docking separately.
The ground comparison is an estimate, not a guarantee of the flown path, fuel use or completion exactly at MEET. Final settling can take additional time. If the achieved insertion state cannot support the transfer, DOR disconnects with a reason such as NO TRANSFER AT INSERTION, TRANSFER FUEL SHORTFALL or MEET BURN TIME LIMIT. An expired MEET or invalid target also stops execution. Take control, review the condition and select a new plan when appropriate; DOR does not silently move MEET or declare rendezvous complete at the parking orbit.
Automated ascent alpha
MODE PARKING ORBIT provides a standalone powered climb ending at a circular parking orbit, including VTOL liftoff. The same ascent controller flies the first leg of a ground RENDEZVOUS mission. During atmospheric climb, DOR supplies heading and pitch targets to the ordinary AFCS HDG/PIT controllers and controls thrust. The FMA shows HDG and PIT on those axes. FPA remains available for pilot-selected flight. Select RENDEZVOUS before launch when the whole trip to an orbital target should continue automatically.
- Select MODE PARKING ORBIT on DOR when you want to stop at a parking orbit. Set ORBIT 200 km MSL for the first test; the range is 150–1000 km in 50 km steps.
- Use STEER AFCS to follow the selected HDG or NAV heading for an assigned departure. This chooses the source of the commanded heading, not whether control surfaces or RCS are used. DOR controls attitude and thrust while following that heading. The magenta orbital heading bug and the airborne ORBIT HDG … deg T readout show the desired orbital direction separately. Set the assigned heading or navigation route before engaging.
- Start approximately level on a clear VTOL departure area, with sufficient vertical-thrust authority for the current loaded weight. Flaps and spoilers must be stowed; icing and open bays are unsupported. A runway takeoff remains manual; PARKING ORBIT can also take over an airborne climb.
- In clients with the LAUNCH row, leave LAUNCH AUTO selected to arm the recommended departure: engage DOR to await the comparison and its recommended departure. While comparing it shows ARMED / COMPARING LAUNCHES with no thrust or attitude command. After accepting a completed, current, fuel-fitting estimate it shows ARMED / LAUNCH WAIT and LIFTOFF IN until departure, then starts VTOL automatically. Choose LAUNCH NOW for immediate departure instead. Earlier clients without this row launch immediately on engagement. VTOL first lifts approximately level to 100 m AGL, then transitions to a climb using lift and pitch to direct the main engines. Retract the gear yourself after liftoff. DOR does not operate it.
- When cleared to turn toward the orbital direction, change STEER to ORBIT. This is allowed during execution. No automatic turn is authorized merely by passing 17 km. AFCS may be selected again if needed; monitor the changed flight path.
- Monitor IAS/Vne, AFT, pitch, thrust, fuel and AP/PE. The controller uses current mass, measured aerodynamic forces and separate thrust limits. Pitch and wing lift are preferred for a supported climb, with vertical RCS retained for VTOL, insufficient lift and recovery. Small vertical-thruster corrections are reduced while lift is available and climb rate is tracking. Attitude RCS assistance fades as the available wing/control-surface lift reserve grows, and remains available for VTOL or insufficient aerodynamic authority. Atmospheric heading changes use banked AFCS HDG turns, not orbital flat yaw. DOR keeps HDG/PIT through at least 50 km MSL and until modeled dynamic pressure is at most 500 Pa; a descent to 45 km or pressure rising to 750 Pa restores aircraft steering. These are DOR transition settings, not an atmospheric boundary. If wing reserve runs low before the transition, pitch uses RCS assistance. Above 50 km, a bank limit below one degree shows HDG LIMITED / RCS PIT on DOR: pitch assistance remains, but significant banked heading changes are unavailable in that interval. The FMA retains HDG/PIT until the orbital handoff. Main thrust can use full available authority when required, but follows the requested airspeed and climb rate, so a partial setting can be normal. Near insertion, small corrections use INSERTION / LEVEL TRIM: level pitch with small main/reverse and translation-RCS corrections. Larger corrections can still require a pitched thrust vector. The initial speed schedule leaves margin below Vne. A short-term forecast at 95% Vne or 200°C AFT removes positive main thrust and shows ASCENT LIMIT / IDLE; this is a controller margin, not a guarantee against disturbances.
- In standalone PARKING ORBIT, after parking-orbit insertion settles, DOR disconnects with the usual sound and shows INSERTION COMPLETE / REPLAN. Select RENDEZVOUS and inspect a new plan from the achieved orbit to reach the station. Switching from PARKING ORBIT to RENDEZVOUS preserves the selected absolute MEET deadline. If it is now too soon or has passed, change MEET and review the new plan. Standalone PARKING ORBIT does not automatically complete rendezvous or switch to TVM; ground RENDEZVOUS continues automatically as described above.
During execution, GUIDANCE ONLY / NO ETA / NO BUDGET means there is no continuously updated full-flight time or fuel guarantee; the ground comparison is an advisory forecast. USED records fuel actually consumed. In the altitude/distance view, the green line is measured flight history and the amber line is the advisory powered-climb forecast described above. The controller has no terrain/obstacle avoidance and does not forecast weather along the route. Ground-to-ground SURFACE PLAN remains a separate preview-only objective.
Changing ORBIT altitude, MEET, MODE or LAUNCH cancels execution. While DOR owns atmospheric HDG/PIT, using the lateral- or vertical-mode cycle key releases DOR and its autopilot engagement, then selects the next ordinary flight-director mode. Re-engage the aircraft autopilot deliberately if wanted. VIEW does not cancel it. STEER can be changed during the powered climb without cancelling it; changing STEER during an armed ground wait cancels that wait. Manual attitude or thrust input overrides powered ascent; invalid/stale required data, unsupported configuration or loss of authority can stop execution. Retain control of the flight after a disconnect.
For administrator accounts, DOR automatically records an executed ascent. A ground RENDEZVOUS keeps the same automatic recording through insertion and the orbital transfer; REC need not be switched on separately. Keep both matching CSV files from OrbitLogs, including ascent commands, the insertion handoff, steering selection and actual engine/RCS response. REC remains available for a continuous flight capture through manual flight and later maneuvers. Use the procedure below when recording a manual profile.
Compare launch times with MEET
MEET comparison is available in the ascent leg of ground RENDEZVOUS and in standalone PARKING ORBIT. Select an orbital station or spacecraft while parked. RENDEZVOUS sets its 200 km staging orbit and orbital steering automatically; standalone PARKING ORBIT additionally offers ORBIT and STEER controls. Use Shift + Up/Down to select MEET and Shift + Left/Right to change it in five-minute steps. MEET counts down to an absolute arrival deadline. Allow the COMPARING LAUNCH TIMES... indication to finish before comparing results.
A newly selected ground RENDEZVOUS searches for the earliest accepted MEET within six hours, prioritizing arrival time over fuel. It excludes atmospheric and orbit-reversing transfer estimates and checks modeled fuel and a finite burn-time allowance. FASTEST FOUND / ESTIMATE is the earliest accepted sampled solution, not a proof of the physically fastest possible flight. Long burns and final velocity matching can make actual completion substantially later than MEET.
Use the countdown for future appointments: for a meeting six hours from now, select 360:00 (minutes:seconds). Adjustments are in five-minute steps, within 30 seconds to six hours. Times are not capped at the most economical meeting; later times remain available even if their fuel cost rises again. An explicit edit keeps your chosen absolute MEET. Switching back into ground RENDEZVOUS starts a new automatic fastest search.
The comparison models a VTOL climb to the selected parking orbit and an orbital transfer from its predicted insertion state to the normal five-kilometre trailing rendezvous point. After you explicitly choose MEET, LAUNCH AUTO searches departure times for the lowest modeled total fuel at that meeting among the sampled candidates. LAUNCH NOW evaluates immediate departure only, including the neighboring MEET comparisons. This is a bounded estimate, not a proof of the globally best window or a guarantee of completing the flight at MEET. More time can save fuel, but orbital geometry means fuel need not decrease smoothly with every later deadline.
| Readout | Meaning |
|---|---|
| SEARCH; CANDIDATE / NOT COMMITTED | The comparison is still running. Displayed fuel, heading and insertion figures are provisional. Engaging DOR can arm the wait for completion; it does not launch on these provisional figures. |
| ARMED / COMPARING LAUNCHES | DOR is armed with zero thrust and no attitude command while the comparison finishes. An accepted completed solution starts the committed launch countdown automatically. A completed comparison with no viable solution disconnects DOR with NO LAUNCH AT SELECTED MEET. |
| LAUNCH IN | Recommended remaining time before departure for the selected MEET. With LAUNCH AUTO, engaging DOR commits that departure time. A passed recommendation must be refreshed. |
| ARMED / LAUNCH WAIT; LIFTOFF IN | DOR is engaged on the ground and waiting for the committed departure. The countdown stays fixed rather than following newly optimized recommendations. Thrust remains at zero until departure. DOR off cancels it. |
| FACE ... deg T / AFCS or ORBIT | Initial true heading for that candidate. AFCS assumes the currently selected departure heading is retained throughout the modeled climb; it does not predict future NAV/ATC route turns. ORBIT follows the selected target's orbital direction. The target's current line-of-sight bearing is not the insertion heading. |
| INSERT IN | Estimated time from now to parking-orbit insertion, including the suggested ground wait. |
| ASC / XFER / TOTAL | Estimated fuel in kg: waiting plus powered ascent, the subsequent ideal orbital transfer, and their sum. A shortfall is shown separately. These figures are not all-inclusive fuel reserves. |
| MEET -5m / MEET +5m | Estimated fuel for deadlines five minutes earlier and later. The initial fastest result compares these at its selected departure; a manual-MEET search compares sampled departures for each deadline. Change the MEET row to select one of those deadlines and recompute its departure recommendation. NO FIT means no accepted candidate was found in that comparison, not proof that every possible trajectory is impossible. |
The comparison uses current loaded mass, available thrust, engine spool, airfoil curves, Vieneo rotation/gravity and the current measured atmospheric conditions with an altitude temperature/density model. It keeps the current landing-gear drag throughout the forecast and holds the chosen steering policy; retracting gear or changing steering alters the flown result. Changing weather, turbulence, clouds, terrain, detailed bank/elevator dynamics, attitude-RCS fuel and later rendezvous correction fuel are not included. The orbital transfer portion uses the existing instantaneous-burn estimate with a finite-burn time allowance. A ground RENDEZVOUS automatically solves that portion again from actual insertion state and fuel. Standalone PARKING ORBIT ends at insertion and requires selecting RENDEZVOUS separately.
A VTOL READY indication describes current ascent-controller readiness. It does not turn an unavailable or fuel-short MEET comparison into an approved whole-trip plan. The altitude/distance plot compares the modeled powered climb with measured flight history; a forecast is not a guarantee of the flown path. The ground comparison normally stops after liftoff. If manual departure occurs before the automatic MEET search finishes, DOR can estimate the remaining climb from the measured airborne state. Airborne ascent shows live pitch, thrust, target TAS/climb, IAS/AFT and fuel used.
Scheduled launch and airborne pickup
LAUNCH AUTO is the default. Select it with the normal Shift + arrow controls. With VTOL ready, engaging DOR during a pending comparison arms ARMED / COMPARING LAUNCHES. It issues no thrust or attitude command until a completed solution has been accepted and its launch countdown reaches zero. A completed estimate must have been checked against current inputs within 30 seconds, offer a future departure (or a current NOW recommendation), and fit the modeled fuel. NO LAUNCH AT SELECTED MEET, REFRESH LAUNCH ESTIMATE, LAUNCH TIME PASSED or LAUNCH FUEL SHORTFALL means DOR has not accepted the departure. Review the condition and re-engage after correcting it. LAUNCH NOW evaluates immediate departure when you choose the takeoff time yourself; ground RENDEZVOUS still requires the completed, fuel-fitting immediate-departure estimate. Standalone PARKING ORBIT NOW does not require a rendezvous estimate.
While armed, DOR commands no thrust or attitude change and does not operate the brakes. Remain parked on the clear departure area. Engagement authorizes automatic liftoff at the committed time; it does not obtain ATC clearance. If clearance is still pending, leave DOR off. DOR off or manual attitude/thrust input cancels the wait. Leaving the ground early also cancels it. Changes to the target/trajectory, steering, plan, power, vehicle/configuration, or material weather/performance inputs can cancel the wait rather than launch using an invalid forecast. Idle fuel use is accounted for. A missed timer requires rearming; DOR does not launch late automatically.
Manual ATC departure: select MODE RENDEZVOUS and MEET while still on the ground, leave DOR off, and take off manually. The pending ascent leg is retained for airborne pickup. Choose standalone MODE PARKING ORBIT instead if you want guidance only as far as a parking orbit. Once you want DOR to take over and ASCENT READY is shown, engage it. Airborne engagement immediately initializes guidance from your current position, velocity, attitude and loaded mass; LAUNCH AUTO does not make an airborne vehicle wait for the old ground time or repeat the ground liftoff. For RENDEZVOUS, engage only when cleared to follow the orbital direction. In standalone PARKING ORBIT, STEER AFCS can retain the assigned HDG/NAV departure until you select STEER ORBIT.
Pickup still needs valid current vehicle/air data and the supported configuration. Engagement is refused above 95% Vne, at 200°C AFT or hotter, or more than 50 km above the selected parking-orbit altitude. Those are controller eligibility limits, not proof that every accepted flight can recover. The ground timing/fuel forecast no longer describes a manually flown departure. A retained ground RENDEZVOUS continues automatically after insertion, using the achieved orbit and original absolute MEET; an infeasible transfer stops with a reason. Standalone PARKING ORBIT ends at insertion. For administrators, automatic mission recording includes the armed wait and launch countdown.
Recording an ascent
These recording controls require an administrator account. In clients with REC ON (FLIGHT), administrators can use REC in every objective, including when ASCENT PROFILE REQUIRED is displayed. Recording observes the flight; it does not engage DOR, supply an automatic ascent pitch/throttle schedule or change ATC routing. A recording is calibration evidence, not an executable profile loaded into the ship.
- Before takeoff, select the intended station or spacecraft and open DOR. Select REC with Shift + Up/Down, then press Shift + Left/Right. With no proposed path, the row reads REC ON (FLIGHT).
- Fly your normal comfortable ascent using manual controls or appropriate existing Autoflyte modes. Follow ATC headings/fixes and make your normal gear, flap, throttle and pitch changes. There is no required 15-degree or 60-degree test attitude.
- Leave REC on through the thin-atmosphere transition and orbital insertion, including any later DOR maneuver. Changing target, planning controls, VIEW or MFD page does not stop a FLIGHT recording. It remains flight-only even if a plan subsequently becomes available.
- Once established in the intended orbit, turn REC OFF. Keep both matching DOR-N.csv and DOR-N-plan.csv from OrbitLogs beside the running executable. Note the vehicle, starting load and any unusual weather or ATC interruption when returning the files.
The flight CSV records current mass/fuel, available and delivered thrust, actual pitch/roll/heading, angle of attack, air-relative flight-path angle, radial climb speed, tangential inertial and ground-relative speed, air-data freshness, IAS/TAS, dynamic pressure, AFT, configuration and Autoflyte modes. It distinguishes vehicle attitude from velocity direction. The companion file contains the capture origin and any available current/target trajectory context; it contains no invented reference ascent. Recording stops on REC OFF, loss of administrator permission, vehicle/simulator state reset, client exit, a file error or the size cap. Copy both files before further tests reuse their slot.
If a proposed path exists when REC starts, the row instead reads REC ON (REF). That captures a frozen reference and follows the stop rules under manual reference recording. REF recordings end when the target or planning controls change, or when DOR execution begins.
Change or circularize your orbit

- Select MODE → ADJUST ORBIT.
- Choose LOCK NONE, LOCK AP or LOCK PE. Locking an apsis preserves its selected radius while you change eccentricity. It does not mean “wait to burn at that apsis.”
- Change e. With LOCK NONE, also change SIZE. Shift+C on the e row requests a circle; without an apsis lock it uses the planned first-burn radius when available, otherwise your current radius.
- Choose the departure rule under START. Compare the green current orbit with the amber requested orbit, AP/PE, burn count, fuel and warnings.
- Engage DOR when satisfied with a valid plan, or use the plan as a reference for manual flying.
START NOW asks for a solution from your current position; you do not have to wait for apoapsis or periapsis. START AUTO compares a limited set of candidate departure times, including apsides for orbital adjustment, and chooses the lowest delta-V among valid candidates. It is not a search of every possible launch window. START AT TIME exposes an IN countdown that you can adjust.
If the requested orbit does not pass through the departure point, the planner may propose a transfer and a second burn to establish the new shape. A request that intersects the surface is rejected. SIZE changes in 100 km MSL-altitude steps, from 100 to 50,000 km MSL; e changes in 0.01 steps. For example, SIZE 600.0 km MSL with e = 0 requests a 600 km circular orbit. You do not add the planetary radius. With nonzero e, SIZE is the midpoint of the AP and PE altitudes, so check both endpoints and PLAN MIN ALT before execution.
Rendezvous with a station or spacecraft
For a surface departure, use Ground-to-rendezvous mission. The steps below describe a rendezvous beginning in free flight, after the ascent leg is complete.
Orbital pressure advisories trigger above 10 Pa. This operating tolerance applies consistently to current-coast, transfer, target and live DOR pressure checks, including OVERFLY's pressure criterion. YSP at 118 km produces approximately 6.3 Pa in the existing client density model, so its orbit alone no longer raises ATMOSPHERIC TARGET. The separate red below-100-km warning and OVERFLY minimum altitude still apply. Targets explicitly in atmospheric-flight reference mode still receive a target warning. Fuel, thrust, orbital-direction and finite-burn checks remain separate; this threshold change does not alter station fuel use or simulate heating.

- Select the target on the navigation/target instrument, then choose RENDEZVOUS here.
- Set MEET to the desired future arrival time. Each adjustment changes the requested interval by five minutes and establishes a new countdown. The adjustment uses the remaining time currently shown, with limits of 30 seconds to six hours.
- Compare START NOW, AUTO or AT TIME. If no clear transfer is found, change the arrival or departure time.
- Use PLANE 3D or EDGE-ON to inspect the plane change, and ORBIT to inspect the transfer shape. Review both burns and the fuel estimate.
- Engage DOR to execute the selected solution. Continue monitoring the target and warnings.
The planned meeting point is approximately 5 km behind the target along its trajectory. It is a rendezvous staging point, not a docking port or a command to fly into the station's center. Stations follow their modeled motion. Another spacecraft is predicted to coast; if it maneuvers, the original prediction is no longer reliable.
After rendezvous, use the normal close-approach and docking procedures. The Orbit page does not obtain docking clearance or perform docking. TVM remains a separate target-relative velocity control.
Planning inside a station control area

Within a station's control area, a station-relative coordinate frame is used for smooth motion. Entering it does not mean the ship is docked. You can plan and execute orbital maneuvers while undocked inside it, and select another undocked spacecraft in a station control area as a rendezvous target. Entering or leaving the control area alone does not cancel DOR. Actual docking at a station permits planning but blocks DOR arming and execution. Previews use the ship's current position and velocity carried by the station. You can inspect RENDEZVOUS, ADJUST ORBIT, OVERFLY and SURFACE PLAN, including their time controls, while attached. Undock before engaging an executable orbital plan; undocking alone does not arm DOR. The selected deadline remains a countdown, so review the updated solution before engagement. Docking during execution cancels DOR.
Orbit reconstructs a ship's state from the station's modeled instantaneous motion plus the ship's measured relative motion. This avoids the jumping orbital elements caused by subtracting two rounded station positions to estimate velocity. It applies regardless of whether the selected target is a station, a spacecraft or a ground point; no display smoothing delays the values.
Follow DOR through the burns
DOR follows the selected executable orbital plan. SURFACE PLAN cannot engage DOR, even when a route says MODEL FIT. REENTRY in the automated-entry alpha has a separate powered-entry controller. During ALIGN and active burns of executable orbital plans, DOR steers pitch and yaw with rotational RCS, points the nose along the commanded burn direction for forward main-engine thrust, and rolls wings level relative to Vieneo's local horizon. The existing flight director receives burn pitch/heading targets and a level-roll reference; Orbit adds no separate attitude-command panel. In WAIT/COAST these remain guidance for the next burn, not a direction the ship must hold. Near a vertical burn, the horizon roll reference is ambiguous, so the controller preserves a stable roll orientation. DOR does not turn on the aircraft Autoflyte autopilot to do this.
-
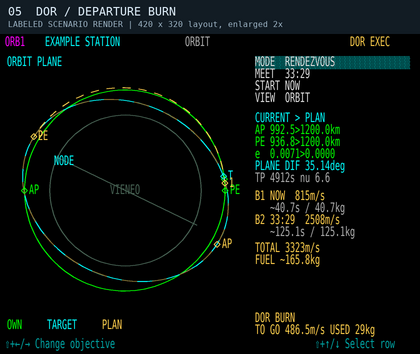
Scenario 5: departure, 30 seconds after engagement. DOR BURN; TO GO is about 487 m/s. The B1/B2 rows retain the planned burn budgets.
-
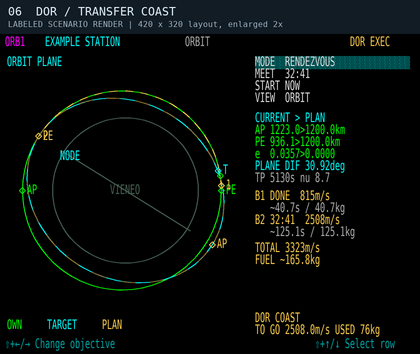
Scenario 6: the same transfer coasting. B1 is DONE. DOR COAST applies no translation thrust and prepares guidance for the next burn; TO GO now refers to that next correction.
-
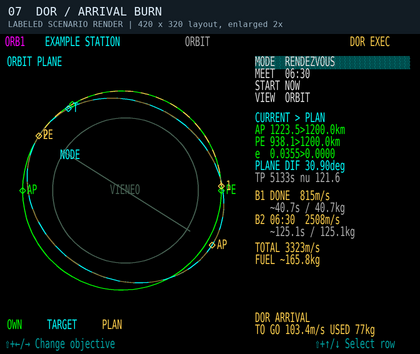
Scenario 7: arrival correction. DOR ARRIVAL has begun before the planned meeting time. Live TO GO differs from the original B2 estimate as guidance corrects the actual trajectory.


ALIGN uses rotational RCS before allowing a burn. It captures within 2 degrees with total angular rate below 0.5 degree/second for at least half a second; more than 5 degrees of attitude error or 2 degrees/second of angular rate returns it to ALIGN. The commanded slew rate is limited to 5 degrees/second per body axis, with braking based on available torque. These are Rise control settings, not an Earth aircraft envelope. Small velocity trims below 2 m/s within the same burn phase retain the established nose direction instead of chasing a reversing near-zero vector; bounded translation controls handle those trims.
The controller uses the vehicle's existing RCS force caps, inertia, lever arms, current mass, installed augmentation-system health, wing damage, electrical power and wear. Rotational effort consumes fuel through the existing propulsion model. DOR can use installed rotational RCS independently of the manual augmentation toggle and its IAS fade. It does not teleport attitude or grant extra torque. Main-engine spool-down and translation-RCS filtering still take time; holding commands off is not an instantaneous removal of residual thrust. The main engines do the bulk orbital acceleration. While aligned, transverse RCS supplies a proportional correction to the thrust direction; small terminal trims retain their separate translation authority. IDEAL duration/fuel and ALL USED measure different things: the former is a main-engine estimate, while the latter includes the fuel actually consumed by all thrusters and idle operation since engagement.
WAIT and COAST allow free attitude control. You may turn the ship in pitch, yaw and roll to look around while DOR remains engaged and the route stays armed. DOR does not force an immediate return to the next burn direction. With the controls released, gentle rotational RCS follows the changing local horizon, lowering the nose as a forward-facing ship travels around Vieneo. It preserves your chosen attitude relative to that changing horizon rather than forcing the nose onto the flight path or restoring level roll. This uses measured motion and planet rotation, not an Earth orbit rate or an altitude cutoff.
When the executor requests a departure, correction or arrival burn, DOR switches to ALIGN, reacquires the burn direction and level roll, and waits for pointing/rate capture before allowing translation thrust. WAIT/COAST alone never command translation thrust. START NOW or reaching a scheduled burn time does not bypass ALIGN. Looking away may therefore add alignment time before the next burn, and the clearance check can refuse that delay. During active burns, remaining delta-V is recalculated from the actual state; it need not decrease smoothly or equal the original burn budget. Completion requires the controller to settle near its goal, so finite burns can finish later than the initial estimate.
Rendezvous completion and TVM
After a successful RENDEZVOUS, DOR automatically hands control to TVM with TVM SET 0.000 km/s, keeping the same selected station or spacecraft. The page reports RENDEZVOUS COMPLETE / TVM and the normal Autoflyte disconnect sound plays once as DOR switches off. This happens when the final position and velocity correction settles, not simply when MEET reaches zero or B2 starts.
TVM commands a velocity match with the selected target; it does not hold the 5 km trail position or provide collision avoidance or automatic docking. Monitor separation and take control for the final docking approach. A manual DOR cancellation or an automatic abort does not engage TVM. ADJUST ORBIT and OVERFLY finish with their normal DOR disengagement.
Powered correction clearance
DOR rechecks each correction from the measured state using a finite powered forecast with Vieneo gravity and the same guidance retargeting law. It budgets alignment as unpowered coast, reserves engine spool and reverser response time, then credits bounded available thrust. Main-engine authority includes current mass, wear, engine health, power and the existing engine derating; small trims use the weaker translation limit. WAIT and COAST receive no hypothetical thrust credit.
The powered-correction check retains surface clearance for RENDEZVOUS and ADJUST ORBIT and the stricter 100 km / 10 Pa requirements for OVERFLY. OVERFLY still checks the remaining approach and continuing orbit and reduces optional position-closing commands that would spoil clearance.
The forecast is a bounded two-body estimate with constant mass and ideal steering after alignment. It is not a complete actuator, drag, lift, terrain or heating simulation. DOR rechecks when actual measurements change; unavailable authority, inadequate alignment time, or an unsafe powered response can still disconnect it. This vacuum correction forecast applies to the orbital leg. Powered launch/ascent and REENTRY use their separate controllers; final descent and landing remain manual.

If no qualifying correction exists, DOR clears its thrust and attitude commands, disconnects with the existing sound, and retains a reason such as DOR: NO CLEAR CORRECTION, DOR: CORRECTION MARGIN LOST, DOR: FINAL ORBIT UNSAFE or DOR: COAST CLEARANCE LOST. A delayed departure can report DOR: DEPARTURE COAST UNSAFE. Alignment checks the measured unpowered path for the estimated turning time and engine response, followed by the powered correction: DOR: ALIGN MARGIN LOST means it cannot safely spend that time turning. OVERFLY retains its atmospheric-clearance requirement; other orbital objectives retain their existing surface-clearance checks and atmospheric cautions. DOR: NO ATTITUDE CONTROL means the attitude data or required rotational authority is unavailable. Disconnecting does not recover an unsafe trajectory. Inspect your actual PE and warnings, then take over or select a different valid recovery plan.
Use DOR off to take over. Manual thrust-increase/decrease key commands also disengage it. Pitch/yaw/roll inputs in WAIT or COAST leave DOR engaged. During ALIGN or either active burn (BURN or ARRIVAL), a pitch, yaw or roll key command disconnects DOR immediately; joystick pitch, roll or yaw input outside the configured dead zone also disconnects it. Those disconnects use the existing Autoflyte disconnect sound. Stale guidance, invalid control data and Flight Freeze suppress rotational commands. Normal control resumes through the existing manual controls after disconnect. Changing planning values, losing/changing a rendezvous target, losing cockpit power, docking/landing, or changing/resetting the vehicle's flight state cancels execution. After a cancellation, inspect the reason and solve again before re-engaging. VIEW changes alone are safe to make during execution.
Every transition from DOR on to off plays the existing Autoflyte disconnect sound once. This includes normal plan completion, automatic aborts, manual takeover, switching to TVM, and a disconnect caused by loss of cockpit power. Completion and abort messages remain visible so you can inspect the reason. Remaining off does not repeat the sound, and restoring power does not replay it; engaging DOR again re-arms the next disconnect. This behavior follows DOR engagement, without an altitude or airspeed cutoff, and also applies in the simulator.
Pass over a ground point

- Select a surface waypoint, then choose OVERFLY.
- Set ALT above the spherical reference surface, in 100 km steps, and PASS time, in five-minute steps.
- Select EXIT COAST to continue on the transfer orbit after the crossing, or EXIT CIRCULARIZE to establish a circular orbit after passing the waypoint.
- Set START, inspect the ground track and orbit views, and review the burn estimates before using DOR.
On entering OVERFLY, the planner searches for an early viable PASS time using the selected ALT, EXIT and START settings. It checks the route and continuing orbit against the OVERFLY clearance requirements below, available fuel and the preview's burn-duration limits. Automatic PASS suggestions also exclude orbital reversals. It searches up to six hours ahead in 30-second intervals, refines the first viable interval to one second, and adds up to 30 seconds of headroom when that later candidate also passes the checks. This is a useful starting estimate, not a guaranteed global minimum or a guarantee of flight performance. Very narrow windows can be missed. It does not minimize fuel.
While searching, FINDING PASS TIME replaces the plan and DOR cannot engage it. NO VIABLE PASS IN 6H means no candidate met these criteria in the bounded search; it does not prove that no possible route exists. Change ALT, EXIT or START, or choose a manual PASS time to inspect other estimates. Weather at the selected point is not an input to the transfer solver.
The initial countdown stays fixed once selected. Until you edit PASS directly, changes to ALT, EXIT or START/IN request a new suggestion. After a direct PASS edit, your chosen deadline is retained, including an invalid or warning-producing one; the planner does not silently move it back into a valid window. Decrease or increase the displayed remaining time in five-minute steps (30 seconds to six hours). To request another automatic starting estimate, leave OVERFLY and select it again. VIEW changes do not restart the search. Automatic suggestions never change an executing DOR plan; manually changing planning values still cancels execution.
The older illustration above demonstrates the layout, not automatic PASS initialization. The clearance illustration below is a labeled code-generated scenario, not a live-flight capture.
Why a low pass may have no clear transfer: Reaching 200 km above the point is not enough if the approach dips into the atmosphere or the continuing orbit returns there. EXIT COAST requires the full continuing orbit to remain bound and clear. EXIT CIRCULARIZE adds an arrival burn, but cannot make an earlier atmospheric dip acceptable. Changing PASS, ALT or EXIT may produce a valid route. Manual PASS retains your requested deadline and may display a blocked trajectory; it cannot override OVERFLY atmospheric clearance. Long-burn estimates can still be inspected manually.
Overfly meets a moving ground location at a chosen time; it does not hover above it. A circularization burn belongs after the crossing and can change where the spacecraft travels afterward. The pass altitude is not clearance above local terrain.
Overfly atmospheric clearance
OVERFLY checks the waiting coast, approach to the waypoint and continuing orbit. Each must stay at or above 100 km MSL and have a conservative dynamic-pressure bound of 10 Pa or less. EXIT CIRCULARIZE also checks the unbraked arrival path over an estimated response interval before crediting the final circular orbit. A clear later circle does not excuse an earlier low pass. The solver prefers a qualifying transfer over a cheaper atmospheric alternative.
The pressure estimate uses the client's 3.063 kg/m³ surface density, 7.5 km scale height and a conservative bound on air-relative speed at the lowest point of the checked arc. At orbital speed, this can require clearance higher than 100 km. These are operational planning checks, not a validated heating envelope, drag-integrated trajectory or guarantee of finite-burn performance. Vieneo's nitrogen/sulfur-dioxide/oxygen atmosphere is retained; no Earth heating coefficients or new atmospheric boundary are introduced. The published Vieneo scale height is 7.5 km, matching the client and server models.
Steady red PLAN MIN, COAST MIN or CORRECTION MIN identifies which trajectory falls below 100 km, with its minimum altitude in km MSL. EXEC PATH <100km identifies another low path checked by the executor. These can warn while your present altitude is much higher. The current-coast indication clears at 105 km to prevent flicker; its displayed number remains the actual predicted minimum during that hysteresis interval. This does not relax the solver's 100 km limit. Ground/reset state clears stale orbital warnings. Pressure advisories such as COAST ATM q>10Pa stay amber when there is no low-altitude warning. Warnings remain visible during both EXEC blink phases and after an abort.
A blocked preview shows NO PLAN, ATM PASS - NO PLAN and MIN … km / BLOCKED where a rejected trajectory is available. DOR cannot engage that preview. Atmospheric penetration remains possible to display for other orbital objectives, and the atmospheric stages of SURFACE PLAN remain planning-only; this OVERFLY restriction is not a blanket exclusion of atmospheric flight or reentry.
Cockpit Q is forward dynamic pressure in lb/ft²: Q = 2 is about 96 Pa, not 2 Pa. It is not a direct temperature or burn-up indication, and the planner's conservative arc-pressure bound is not the same as that instantaneous cockpit component.

Surface journey planning
For a ground or low-atmospheric departure, select point B on the normal target instrument. On this page choose MODE SURFACE PLAN, then ROUTE and TRIP while on the ground, or PASS when already airborne. For a departure from orbit or an orbital station, use the REENTRY controls below instead. Docking prevents execution, not planning. SURFACE PLAN remains planning-only after undocking; a qualifying REENTRY plan in the automated-entry alpha can be executed.
Local trips: SURFACE PLAN shows NO PLAN / TOO SHORT when the departure and destination are less than 5 km apart, including their height difference. It does not generate a climb path, fuel estimate or initial time search for these trips. A coincident destination on the ground shows ALREADY AT B. Fly the local hop using ordinary flight controls or suitable Autoflyte modes; changing TRIP/PASS or forcing ATM, SUB or ORB does not create a local takeoff/hover/landing profile. This is a limit of the surface planner, not a vehicle flight limit. Orbital REENTRY and an entry already in progress are exempt.
| ROUTE | Proposed profile |
|---|---|
| AUTO | Compare the three route families at the selected TRIP duration or PASS deadline. Choose the lowest estimated fuel among candidates that pass the simplified model checks. AUTO may choose a different family when the selected time changes. |
| ATM | A powered atmospheric profile, climbing to 20 km MSL, traversing toward B, then descending. Only offered for departures at or below 40 km in this initial model. It is not a simulation of wing-borne cruise. |
| SUB | Powered climb and boost, a ballistic coast with a surface-intersecting osculating orbit, then powered braking and descent. The coast ends before the intersection. |
| ORB | Powered climb and boost, a circular coast nominally at 400 km MSL, then powered braking and descent. This need not complete a revolution. |
TRIP is the requested travel duration before departure. While on the ground with REC off, it stays steady: TRIP 30:00 means a 30-minute journey starting when you depart. Waiting on the ground does not consume that allowance or make the same route require more thrust and fuel. At liftoff the deadline is fixed and the row becomes PASS, counting down to arrival. For administrators, starting REC also fixes the reference at capture start, even if you are still on the ground; it must not slide forward during a calibration recording. Ending REC while still grounded restores the selected TRIP duration. Landing with REC off also restores duration planning. An already-airborne surface preview uses PASS from the time it is selected.
Adjust TRIP/PASS in five-minute steps using the value shown (30 seconds to six hours). This is a timing constraint, not an AUTO preference switch. The comparison shows each family's estimated fuel and MODEL FIT, THRUST LIMIT, FUEL LIMIT, IAS LIMIT or another reason. A forced ATM/SUB/ORB choice is retained even when invalid; AUTO does not silently replace it. If nothing fits, AUTO can display a rejected candidate for inspection. The upper-right header says INVALID in red; PLAN ONLY is reserved for a fitting preview, and NO PLAN means no candidate is available. The rejected path and estimates remain visible to help you adjust the timing; they are not achievable flight commands. Longer times are not guaranteed to help: gravity support consumes fuel and the search covers only a limited family of profiles.
On first selecting this objective, the module searches for an initial model-fitting trip time up to six hours: two-minute trial spacing, ten-second refinement of the first fitting bracket, and up to 30 seconds of headroom if that candidate also fits. FINDING TRIP TIME identifies the grounded search; NO FITTING TRIP IN 6H means this bounded search found none, not that every possible trajectory is impossible. Airborne previews use FINDING INITIAL PASS / NO FITTING PASS IN 6H. A manual edit keeps your chosen duration or deadline, including an invalid one. Changing ROUTE requests a new suggestion only before the time has been edited manually. Leaving and reselecting SURFACE PLAN restarts automatic initialization. The search never rewrites an executing orbital plan.
The amber path joins the measured initial state to B's position at PASS, accounting for Vieneo's rotation. PLANE 3D and TRACK can show the whole journey even before takeoff. For space profiles, markers 1–4 indicate the end of climb, start of coast, start of braking and start of descent/entry; B is the future destination. These are preview phase boundaries, not flight-director commands. ATM has only its final B marker. The top flight-phase label describes your current state, independently of the proposed route.
| Surface readout | Meaning |
|---|---|
| RANGE | Current great-circle distance to B, in km; not full path length. Below 10 km, one decimal place is shown (for example, 0.5 km). |
| TOP | Highest sampled profile altitude, km MSL above the spherical reference surface. |
| TOTAL | Integrated powered acceleration, expressed as delta-V in m/s, including gravity support and modeled body drag. This can greatly exceed the vehicle's speed; it is not a cruise-speed command. |
| FUEL | Estimated kg for the selected ideal profile, including idle flow during coasts. |
| THRUST | Peak fraction of available main-engine thrust. More than 100% is shown in red and invalidates the candidate. If IAS also exceeds its limit, the reason reads IAS / THRUST LIMIT so neither failure is hidden. |
| MAX q | Highest sampled dynamic pressure in kPa, based on mass density and air-relative speed. It is informational, not a validated heating or structural limit. |
MODEL FIT is not flight clearance. The preview uses Vieneo gravity and rotation, the client's 3.063 kg/m³ surface density and 7.5 km density scale height, vehicle main thrust, altitude efficiency, fuel flow, wear and empirical body drag. The published Vieneo scale height matches the 7.5 km used by both client and server. Cruise at 20 km, the 100 km powered-segment interface and nominal 400 km orbital coast are planning choices, not atmospheric boundaries.
These ground-departure powered segments assume ideal thrust direction. They do not simulate RCS-axis limits, vehicle attitude changes, spool response, wing lift, wing/tail/wave drag, wind, clouds, weather avoidance, heating or terrain. ATM supports weight with thrust, so its fuel estimate is not a prediction of ordinary wing-borne Autoflyte cruise. Sampled geometry checks a reference sphere; it does not establish terrain clearance or that point B is a suitable landing site. Fuel comparisons and AUTO's choice are therefore comparisons within this simplified model, not a global optimum or a recommendation to fly the displayed path. Direction reversals remain visibly cautioned.
PLAN ONLY / ATM HANDOFF means the atmospheric stages require separate pilot/Autoflyte operation. SURFACE PLAN provides no automatic mode handoff, takeoff, atmospheric guidance, hover or landing. Orbital REENTRY has its own alpha controller described below. The end-state is an ideal planning endpoint at B, not a landing command. Pressing DOR on a surface preview leaves execution off and plays the Autoflyte disconnect cavalry sound once to acknowledge the refusal. Holding the key does not repeat the sound. Existing executable ADJUST ORBIT, RENDEZVOUS and OVERFLY plans remain separate.
The dated scenario illustrations below use the earlier PASS label before takeoff; current ground previews display TRIP.
-
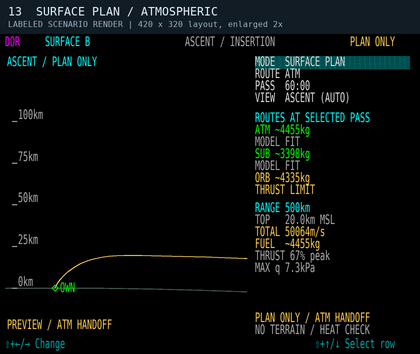
Scenario 13: ATM, 500 km in 60 minutes. Local ascent preview and route comparison. The large TOTAL includes ideal powered gravity support. Labeled synthetic render, not a live flight.
-
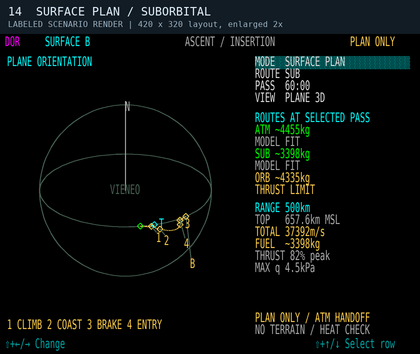
Scenario 14: SUB at the same PASS. Whole-route PLANE 3D view while still on the ground, with ballistic coast and numbered phase boundaries. Labeled synthetic render.
-
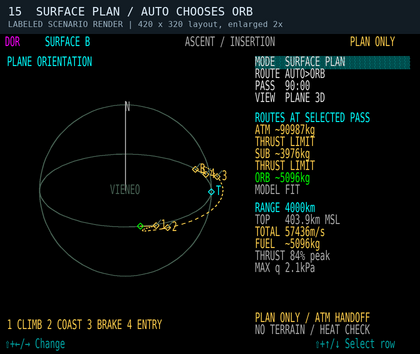
Scenario 15: AUTO, 4000 km in 90 minutes. ORB fits the simplified model while ATM and SUB exceed thrust. This demonstrates the PASS constraint, not certified flight performance. Labeled synthetic render.


Reentry and atmospheric entry
Select the intended surface waypoint on the usual navigation instrument. For an orbital departure, choose REENTRY. Planning is available while docked; undock before engaging DOR. The automated-entry alpha can fly an ENTRY READY profile from at least 100 km MSL to its atmospheric handoff. It requires current air data, main/reverse and translation thrust, and a clean configuration: gear, flaps and spoilers retracted, bay closed and no significant icing. A plan lacking those inputs, or newly planned below 100 km, remains PLAN ONLY. Earlier calibration clients label this mode REENTRY PLAN and cannot execute it.
The initial handoff is 30 km MSL at 0.5 km/s TAS, upstream of the selected surface point. These are adjustable test conditions, not universal safe limits. The handoff is level flight aimed toward the surface point; it is not touchdown. HANDOFF counts down to that atmospheric transition, not touchdown at the waypoint. The planner estimates the remaining glide reach using the vehicle's clean-air aerodynamic data. FINAL HOLD retains that general-purpose handoff. The arrival-planning alpha also offers runway/hover previews described below. None establishes obstacle clearance or an achievable unpowered glide all the way to B.
| Control | Meaning |
|---|---|
| ROUTE AUTO | Compare direct powered entry and coast-then-entry at the selected handoff time. Among model-fitting candidates, choose the lower estimated fuel requirement. This is a bounded search, not a global optimum. |
| ROUTE ORB | Remain on the measured current orbit for a selected coast, then enter. The preview does not first force the ship into a nominal 400 km orbit. |
| ROUTE SUB | Begin a direct powered entry after allowing time to align, without a discretionary orbital coast. Its feasibility depends on the requested time, position, velocity, weight and available thrust. |
| H ALT | Atmospheric handoff altitude, km MSL. Adjust in 5 km steps, from 15 to 60 km. |
| H TAS | Air-relative handoff speed, km/s. Adjust in 0.1 km/s steps, from 0.1 to 1.5 km/s. This is not IAS or orbital speed. |
| HANDOFF | Requested remaining time, adjusted in five-minute steps. A shorter time may require greater powered acceleration or braking, or have no fitting candidate. |
| REC | Administrator-only: record a manual test and the selected reference plan without engaging DOR. See below. |
ATM remains an atmospheric-departure option in SURFACE PLAN. It is not offered as an orbital entry shortcut. Ground/low-atmospheric SURFACE PLAN retains its separate AUTO / ATM / SUB / ORB route families and TRIP/PASS arrival at B; the new entry controls describe an atmospheric handoff before B.
D marks deorbit/start of the powered profile, E the sampled crossing of 100 km, and H the atmospheric handoff. The 100 km marker is an operating reference, not a hard atmosphere boundary. Gray is the planned coast on the current orbit; amber is the proposed powered entry. The graphic area remains the same size in every view.
REV and RCS show peak required fractions of the corresponding available thrust. The entry model uses current loaded mass, fuel consumption, main-engine condition, separate forward/reverse and up/down/side limits, engine response, Vieneo gravity/rotation/density, and the client's clean wing/tail/body and Mach-dependent aerodynamic model. It estimates AFT from the client's heat-transfer model. MAX q is the modeled effective aerodynamic pressure in kPa, including the client's Mach augmentation; it is distinct from ambient-density dynamic pressure. Cockpit Q is in lb/ft². LOAD is estimated non-gravitational acceleration in standard Earth g units.
The alpha's preview reports peak IAS as a percentage of Vne and peak predicted AFT. It requires at most 95% of Vne, 200°C predicted AFT and 95% of each available thrust axis, plus its engine-response and attitude-rate checks. These are controller settings for validation, not newly established vehicle limits. AFT forecasting uses Vieneo's model and the current measured temperature/wind; it does not forecast changing weather, clouds or turbulence along the route. ALPHA / NO TERRAIN CHECK remains a limitation: the profile has no terrain or obstacle database and no automated final-descent or landing controller. Keep entry procedures, AFT, IAS/Vne and flight path in view.
Entry readiness and configuration: A route can fit the fuel, thrust and temperature limits while the ship is not ready to execute it. PLAN ONLY with an amber CONFIG LANDING GEAR, CONFIG FLAPS, CONFIG SPOILERS, CONFIG AIRFRAME ICE or CONFIG CARGO BAY identifies the configuration that must be corrected. Air, thermal or performance data problems have their own messages. Retract gear, flaps and spoilers fully, close the bay and clear icing before entry. Landing gear must also have confirmed status: a GEAR DISAGREE condition or unknown gear status prevents entry even if the gear appears retracted. The DOR page continues to show CONFIG LANDING GEAR. READY / ENTRY READY and ARM DOR TO EXECUTE indicate that the entry readiness checks pass; selecting AUTO does not engage DOR.
If gear prevents engagement, DOR remains off, announces its disconnect sound and queues "Config. Landing gear." The refusal is also shown in red. Extending gear or losing confirmed gear status during an executing entry invalidates the clean profile and disconnects DOR, releasing its attitude and thrust commands with the same specific alert. Take control after a disconnect; DOR does not retract gear or automatically re-engage. A new entry still requires an origin at or above 100 km MSL. The queued gear phrase is discarded if the gear is confirmed fully retracted, power is lost, or the relevant vehicle/plan changes before playback. Normal gear use after the achieved atmospheric handoff does not trigger this entry-specific warning; the ordinary aircraft-mode limits still apply.
Automated entry alpha
- Start with a clean ship in orbit and select the surface destination. Use AUTO, H ALT 30 km and H TAS 0.5 km/s for the initial test.
- Adjust HANDOFF until the preview says ENTRY READY. Shortening it asks for a faster journey; IAS RESERVE, AFT RESERVE, THRUST RESERVE, ATTITUDE RATE or SPOOL LIMIT identifies why a candidate is rejected. A longer time is not guaranteed to fit every geometry. Check fuel and the whole proposed path.
- Undock if necessary, then engage DOR. AUTO selects a route; it does not engage DOR by itself. For administrators, an accepted entry starts a CSV capture automatically, so REC is not required for this test. Other accounts fly the same entry without diagnostic recording.
- During coast DOR pre-aligns for entry. During POWERED ENTRY it keeps the nose into the air-relative direction of travel with a small positive angle of attack, using forward or reverse mains and bounded translation RCS. Braking does not require pointing the tail into the airflow. Manual attitude input during ALIGN or powered entry disconnects DOR.
- ENTRY LIMIT / BRAKING means the short-term forecast predicts excessive IAS or AFT. DOR gives braking and descent control priority over the requested time; HANDOFF may be missed. This is active protection, not a guarantee against every disturbance or an instruction to ignore warnings.
- At the achieved handoff, expect the ordinary DOR disconnect sound once. FINAL HOLD transfers to ALT/HDG/TAS hold; a valid runway FINAL selection transfers to ALT/NAV/TAS hold on the inbound course. The autopilot holds the selected MSL altitude and the entry autothrottle holds the selected TAS. It does not descend toward or land at B. HANDOFF PASSED alone is not completion: altitude, airspeed, descent rate, position and attitude must also converge.
- To resume normal flight, cancel the entry TAS hold with the DOR control or by moving a physical throttle lever. The altitude and heading holds remain until changed or disconnected. Disconnecting the aircraft autopilot also ends the TAS hold. In the arrival/FPA alpha, TAS hold continues with HDG, NAV or LOC and PIT, VS, ALTm, ALTa, FPA or G/S. Selecting SpeedPitch, Roll, an off mode or TVM ends it. Ordinary gear/flap/spoiler changes after handoff retain TAS hold with updated drag compensation; icing, an open bay, unavailable/stale air data or lost authority still cancel it. Change H TAS on the DOR page to adjust the held speed. Take over for ATC routing, descent and approach; a fixed TAS can produce increasing IAS as you descend, so reduce it appropriately.
For administrators, automatic recording continues through the handoff holds until they are cancelled. Retain both matching CSV files for review of the actual response, predicted heat/IAS, force commands, available thrust and handoff modes. Start testing with a comfortable preview, then shorten the requested time on subsequent flights; the alpha is not a certified fastest possible entry.
Arrival planning and final approach
These controls require the arrival/FPA alpha, which is newer than the ascent-recording alpha. They are available on REENTRY, not on ground-departure SURFACE PLAN. Choose FINAL with the usual Shift + arrow controls before engaging DOR. A new surface target resets FINAL to HOLD; selecting a destination does not silently authorize an approach or landing.
| FINAL | Preview and handoff |
|---|---|
| HOLD | The default: atmospheric entry followed by ALT/HDG/TAS hold. |
| ILS (PLAN) | Select a live, fully serviceable runway ILS or an outer-marker/LOM waypoint with one unambiguous associated inbound runway. The preview uses the marker's distance when available, otherwise the selected final distance (initially 10 km). Its final gate is 50 m below the nominal 3° beam for an eventual level intercept. The displayed ≤30° intercept is a planning objective for the manual final, not an automatically enforced capture condition. |
| VISUAL (PLAN) | Select a runway threshold with a published inbound heading. A second FINAL row adjusts the extended-centerline distance from 6 to 30 km in 2 km steps; the initial value is 10 km. The gate follows a 3° ray above the runway's local tangent plane, corrected for Vieneo's curvature. Ten km is approximately 0.54 km above the runway; the readout is MSL, so runway elevation is added. |
| VTOL (PLAN) | Preview a hover gate 100 m above the selected surface point. Current vertical-thrust authority must exceed the weight-support requirement at the loaded mass. This is not a terrain-clearance check or a commanded hover/landing. |
Runway selections position the atmospheric entry handoff upstream on the runway's extended centerline and point its ground-relative path inbound. The automated portion still ends at H ALT / H TAS (initially 30 km / 0.5 km/s), not at the low final gate. A successful runway entry transfers to ALT NAV SPD / FINAL MANUAL. The gray final line and FINAL … km MSL / MANUAL altitude are advisory geometry. DOR does not execute that line, descend to the LOM, arm LOC/G/S, flare or touch down. VTOL also retains the atmospheric altitude/heading/speed handoff; it does not switch to TVM or descend automatically.
After handoff, manage the remaining energy and descent with the aircraft controls. For an instrument approach, select the correct runway/radio course and use the normal LOC/G/S controls when appropriately positioned below the glidepath, within a 30° inbound intercept and at a suitable speed. A LOM is a fix, not the runway threshold or the origin of the ILS beam. Airport names and proximity alone do not identify a runway. SELECT RUNWAY / LIVE ILS or SELECT RUNWAY THRESHOLD means the required data are absent or ambiguous. Changing associated approach data during DOR entry stops execution with APPROACH DATA CHANGED.
Flight path angle (FPA)
The normal vertical flight-director cycle is PIT → FPA → VS → SPD → ALTm → ALTa → PIT. FPA follows Pitch directly when available. At ground contact, below 0.010 km/s horizontal groundspeed, or with invalid path data, the vertical-mode key skips FPA and continues to VS, SPD and the available altitude modes. ALTa is skipped when the required ground-height data are unavailable; G/S remains separately armed. FPA captures the current ground-relative climb/descent angle. Use the existing vertical-target increase/decrease controls to adjust it; the selected signed angle appears in the flight-mode display. The selectable range is −15° to +20°. For a descending 3° path, select −3°.
FPA is the angle of travel relative to the local ground tangent, not nose pitch or angle of attack. The controller adjusts pitch as the measured path changes; its pitch command changes by at most 3°/s. Aircraft response, wind, lift and available thrust still determine whether it can achieve the selected path. FPA controls neither lateral course nor speed, and does not provide terrain avoidance, a flare or touchdown. It can be used as a flight-director cue or with the normal aircraft autopilot; it is not an orbital insertion solver or a DOR ascent profile.
At ground contact, below 0.010 km/s horizontal groundspeed, or with invalid path data, FPA returns to PIT at the current pitch. It does not automatically re-arm: select FPA again after establishing forward flight. This prevents a hover or nearly vertical trajectory from being treated as an ordinary forward flight path. Ground-relative geometry remains defined at high speed, but selecting FPA does not establish atmospheric control authority in suborbital coast or orbit.
The CSV records selected FPA/course, AFCS ground/vertical speeds, arrival choice, final-gate geometry and its advisory status. The companion plan file labels the final line final_advisory_not_executed. Actual lateral/vertical thruster output remains recorded; a human's recorded firings are not replayed as the optimal control sequence.
Recording a manual entry test
These recording controls require an administrator account.
- Select the target, route, handoff time, altitude and TAS; wait for an inspectable proposed path.
- Select REC and press Shift + Left/Right once to turn recording on. With the proposed path available, the row reads REC ON (REF). This does not engage DOR or command the ship.
- Fly the test manually or with appropriate existing Autoflyte modes. Changing VIEW or leaving the MFD page does not stop recording. The CSV reference stays fixed at recording start even while the live preview updates.
- Turn REC off to finish. Changing planning controls, changing target, resetting/changing the vehicle, or engaging an executable DOR plan also ends the manual capture. A new test requires REC on again.
- Return both matching files from the OrbitLogs directory beside the running executable: DOR-N.csv and DOR-N-plan.csv. The first contains actual flight data and timed comparison values; the second contains the frozen reference trajectory.
Four reusable file slots bound retention; older captures can be replaced by subsequent starts. A slot stops at 128 MiB rather than discarding its beginning. REC FILE ERROR or REC FILE FULL means capture has stopped. Current clients can start REC ON (FLIGHT) without a reference; older entry-calibration clients instead display REC WAIT FOR PLAN. Copy the pair you want to keep before beginning more tests. No automatic upload occurs.
New captures separately integrate main-engine, translational-RCS, attitude-RCS and idle fuel consumption, and record the available orbital MECO estimate. The tank-based ALL USED remains the measure of fuel actually lost; integrated component totals can differ slightly because of fuel-tank rounding.
The CSV includes time, target, mass/fuel, position/velocity, engine and RCS outputs, air-relative velocity, IAS, Mach, dynamic pressure, measured AFT and reference errors. The automated-entry alpha also records the predicted AFT/IAS reference, the live protection forecast, controller limits, force requests and handoff holds. Earlier calibration captures contain measured AFT but no predicted temperature reference. An expired HANDOFF or end of recording does not prove that the entry was completed successfully.
| Message | Meaning / next action |
|---|---|
| VACUUM ESTIMATE | An orbital estimate is available. It assumes two-body coasting between instantaneous planned burns. |
| LONG BURN - ESTIMATE / FINITE BURN NOT CORRECTED | The preview's instantaneous-burn approximation is weak for the estimated duration. Live DOR corrects from actual state, but the original time, path and fuel are estimates. |
| PLAN ATM PASS / COAST ATM q>10Pa / CORRECTION ATM q>10Pa / CURRENT ATM q>10Pa / ATMOSPHERIC PASS / ATMOSPHERIC TARGET | Pressure advisory above 10 Pa, or a target explicitly in atmospheric-flight reference mode. The actual predicted coast is refreshed during execution. Other orbital modes can retain atmospheric estimates; OVERFLY must satisfy its stricter clearance requirements. |
| PLAN MIN / COAST MIN / CORRECTION MIN / EXEC PATH <100km | Steady red low-altitude warning identifying the affected trajectory. The numerical minima are km MSL. COAST MIN assumes no further burns and can differ from PLAN MIN ALT. The current-coast warning clears at 105 km; this is annunciation hysteresis only. |
| ATM PASS - NO PLAN / MIN … km / BLOCKED | An inspectable OVERFLY candidate fails atmospheric clearance. Change PASS, ALT or EXIT; DOR cannot execute it. |
| DOR: TIMING INTERRUPTED | A simulation frame took more than one second. DOR disconnects because its previous control commands cannot safely cover the interruption. Check the current flight state before re-engaging; this message does not identify the cause of the client stall. |
| DOR: NO CLEAR CORRECTION / CORRECTION MARGIN LOST / FINAL ORBIT UNSAFE / COAST CLEARANCE LOST / DEPARTURE COAST UNSAFE | Execution stopped because the updated trajectory or correction fails its checks. Thrust commands are cleared and the disconnect sounds once. The existing trajectory still needs pilot attention. |
| SURFACE INTERSECTION / NO CLEAR TRANSFER | The requested shape intersects Vieneo, or no acceptable transfer was found. Raise the requested periapsis or change the timing/objective. |
| INSUFFICIENT FUEL / PERFORMANCE UNAVAILABLE | Fuel or propulsion data do not support execution. A geometric estimate alone is not an executable DOR plan. |
| BURN TIME PASSED / ARRIVAL TIME PASSED | The selected deadline has passed. Edit the time to request a new one; these are real countdowns, not indefinitely rolling delays. |
| SELECT NAV TARGET / NO TARGET TRAJECTORY | Select a usable target, or choose ADJUST ORBIT. |
| DOR: UNDOCK TO EXECUTE | An orbital plan can be previewed while attached to a station, but DOR cannot arm or execute it until undocked. Undocking does not engage DOR automatically. SURFACE PLAN remains planning-only. A qualifying automated-entry REENTRY still requires undocking before execution. |
| NO DEPARTURE STATE / POWER OFF | The departure reference is unavailable or unsupported, or cockpit power is off. A valid station attachment permits previews; an unsupported containment frame does not. |
| ASCENT PROFILE REQUIRED | The selected vacuum orbital objective has no powered launch solution. Choose MODE RENDEZVOUS for a continuous launch to an orbital target, or MODE PARKING ORBIT for a standalone parking-orbit climb. Older clients require a manual ascent. |
| VTOL READY / ASCENT READY | The ascent controller is ready with the current inputs. Ground LAUNCH AUTO can arm while its comparison is running, but requires a completed, current, fuel-fitting solution before committing departure; ground RENDEZVOUS requires one for LAUNCH NOW too. This is not a full-flight fuel, time or terrain-clearance guarantee. See scheduled launch and airborne pickup. |
| VTOL LIFT / ATTITUDE LIMIT / ASCENT DATA INVALID | Check loaded vertical-thrust authority, level ground attitude, configuration and valid current air data. |
| ASCENT LIMIT / IDLE | The short-term ascent forecast is at its IAS or AFT guard. Positive main thrust is reduced; monitor the actual path. |
| INSERTION COMPLETE / REPLAN | Standalone PARKING ORBIT has ended at the parking orbit. Select and review RENDEZVOUS separately to continue. A mission begun in ground RENDEZVOUS instead transfers automatically. |
| DOR: NO TRANSFER AT INSERTION / TRANSFER FUEL SHORTFALL / MEET BURN TIME LIMIT | The achieved insertion state cannot support the transfer at the original MEET with the remaining fuel/time. DOR stops; review the condition and a new plan before re-engaging. |
| DOR: MEET MISSED DURING ASCENT / MEET MISSED AT INSERTION / ASCENT TARGET INVALID / INSERTION TARGET INVALID | The mission has insufficient remaining MEET time or no usable orbital target. DOR stops rather than changing the deadline or treating parking insertion as rendezvous completion. |
| PLAN ONLY / ATM HANDOFF | The displayed candidate is preview-only; DOR cannot execute it. Ground-departure SURFACE PLAN remains preview-only. REENTRY needs a qualifying ENTRY READY profile in the automated-entry alpha. |
| INVALID / MODEL FIT / THRUST LIMIT / FUEL LIMIT / IAS LIMIT / IAS / THRUST LIMIT | Result of the surface preview’s simplified checks. MODEL FIT does not certify terrain, heating, weather, maneuverability or landing. |
| NO TERRAIN / HEAT CHECK | SURFACE PLAN and older calibration previews omit these checks. Automated-entry REENTRY predicts heat but still displays ALPHA / NO TERRAIN CHECK. |
| ENTRY READY / IAS RESERVE / AFT RESERVE / THRUST RESERVE / ATTITUDE RATE / SPOOL LIMIT | Automated-entry preview result. READY passes the modeled checks; other messages identify a rejection. None certifies terrain clearance or landing. |
| ENTRY DATA / CONFIG | Entry cannot execute with the current air data, configuration or departure altitude. Check clean configuration, valid measurements and an orbital departure. |
| ENTRY LIMIT / BRAKING | Active entry protection prioritizes braking and arresting descent over the requested handoff time. Monitor the actual trajectory. |
| MODEL FIT / HEAT UNCHECKED | Older calibration-client preview; it does not support automated entry. |
| HANDOFF BELOW TARGET | Raise H ALT above the destination elevation. |
| ENTRY DATA UNAVAILABLE / ENTRY GEOMETRY / NO COAST / ENTRY FIT | Required performance data or a fitting entry candidate is unavailable. Inspect the selected time, route and handoff settings. |
| REC FILE ERROR / REC FILE FULL | Capture stopped because of a file error or size cap. See recording instructions. |
| ENTRY FIRST / NO ROUTE AT THIS PASS | Direct ATM is outside its initial departure-height range, or no candidate was available at this deadline. Change ROUTE/PASS or use separate entry procedures. |